
KK 2.1.5 Flight Control Board
5.0Editor score
Purpose-built VTOL and V-tail support
Self-leveling and aerobatic modes
Designed for customizable flight control
Compare Flight Controllers for Hybrid Vtol and Vtol Drones, comparing firmware support, sensor hardware, connectivity, mounting, and mission readiness.
Flight controllers for hybrid VTOL and VTOL drones must coordinate fixed-wing aerodynamics, vertical thrust, autonomous transitions, and reliable mission planning. A strong unit needs dependable sensors, flexible outputs, appropriate firmware support, and enough connectivity for receivers, telemetry, GPS, and mission-specific accessories.
This guide compares ten boards and integrated stacks based on the supplied specifications, including processor hardware, inertial sensors, interfaces, mounting patterns, battery support, and intended applications. It covers purpose-built VTOL controllers, adaptable open-source platforms, and compact multi-rotor stacks that can also suit hybrid aircraft.
The selections show why there is no universal answer: some builders prioritize dedicated VTOL functions, others want open-source flexibility, and compact racers may need an ESC and controller in one package. Product availability and pricing can change, so verify current listings, accessories, and firmware compatibility before purchasing.
5.0Editor score

4.8Editor score
This side-by-side comparison highlights each controller's processor platform, sensor configuration, firmware flexibility, and physical integration. The list ranges from VTOL-specific boards to open-source autopilots and 30-by-30-millimeter flight-controller-and-ESC stacks for multirotor-based hybrid designs.



The KK 2.1.5 Flight Control Board is the most directly VTOL-focused product in this guide, with a listed rating of 5.0 and a design intended for VTOL and V-tail aircraft. Rather than approaching vertical flight as a secondary function, it emphasizes the control characteristics builders want when combining forward motion with vertical takeoff and landing. That makes it a compelling first choice for hobbyist-scale experimental platforms.
We may earn a commission when you buy through this link, at no additional cost to you.
Its feature set includes self-leveling, aerobatic flying, stability, and customizable flight behavior. The board is presented as suitable for model-aircraft competitions, aerial-photography projects, and skill demonstrations, giving it a broader range of potential uses than a controller limited strictly to hovering. Self-balancing behavior can also make a new airframe more manageable while the pilot learns how the aircraft responds during vertical and forward flight phases.
The main trade-off is transparency compared with open-source ecosystems such as PX4 and ArduPilot. The supplied information does not list processor specifications, interface counts, mounting dimensions, or supported telemetry protocols in the same detail provided for the other products. As a result, this controller is most attractive when its stated VTOL and V-tail focus matches the planned aircraft and the builder wants a straightforward, specialized starting point.
Choose the KK 2.1.5 when dedicated VTOL intent matters more than maximum expandability. Before buying, confirm the receiver protocol, motor and servo signal requirements, firmware, and wiring arrangement for your airframe. It is our best budget recommendation for a compact VTOL learning build, but more complex autonomous missions should favor a controller with a better-documented ecosystem.
VTOL-specific support can reduce the configuration work associated with transition aircraft. The board is expressly positioned for VTOL and V-tail flying, allowing builders to begin with hardware whose stated purpose aligns with the airframe rather than adapting a general multirotor controller.
Self-leveling and aerobatic support give pilots contrasting ways to fly the same aircraft. The leveling mode can help with stable passes and learning, while acrobatic capability provides a more dynamic experience for competitions and demonstrations.
We may earn a commission when you buy through this link, at no additional cost to you.
The COREWING F405 V2 is positioned as a flight controller for both RC airplanes and drones. Its F405 name identifies a widely used high-performance processor family, although the supplied product information does not specify clock speed, memory, sensor details, output count, or firmware compatibility. That limited transparency makes direct technical comparison difficult, but it remains a relevant option for builders who already know this controller ecosystem.
We may earn a commission when you buy through this link, at no additional cost to you.
Its strongest apparent selling point is adaptability across fixed-wing and multirotor projects. A VTOL aircraft contains elements of both: a forward-flight wing and a multirotor-like lift system. A general aircraft controller may therefore appeal to builders who want one platform across multiple airframes, especially if their existing wiring, receiver, and programming setup align with the F405 standard.
The trade-offs come from incomplete supplied information. No rating is listed, and the description does not confirm VTOL transition logic, GPS support, telemetry protocols, redundant sensors, or a quick-start guide. It would be irresponsible to assume that capabilities associated with another F405 board are present here. Buyers should inspect the listing, pinout, manual, and supported firmware before committing to a project.
This is a practical recommendation for experienced builders who can validate the F405 V2's documentation. It is less suitable for someone seeking a clearly documented all-in-one solution. Confirm physical dimensions, receiver types, servo outputs, current handling, and firmware before purchase, especially if the aircraft relies on automated takeoff, waypoint navigation, or mission-level failsafes.
The stated compatibility with RC airplanes and drones makes this controller interesting for builders maintaining more than one airframe. Standardizing on one controller can simplify spares, familiar programming, and repeated installation work, provided its outputs and firmware meet each project.
The F405 processor family is associated with capable real-time control applications. For a VTOL build, that processing foundation is sensible, but the exact implementation still depends on the board's sensors, clock configuration, and firmware.
We may earn a commission when you buy through this link, at no additional cost to you.
The PIX 2-12S is explicitly marketed for VTOL multirotor applications and combines an STM32F405VGT6 controller with several navigation sensors. Its specification detail is among the strongest in the guide, including dimensions, mounting information, receiver connectivity, power range, and the included wiring components. This makes it easier to assess against a real aircraft design than a controller with only a broad application statement.
We may earn a commission when you buy through this link, at no additional cost to you.
The board integrates an MPU6500 gyroscope, VCM5883L magnetometer, and LPS22HB barometer. Those sensors cover core orientation, heading, and altitude-related needs, allowing a builder to evaluate sensor placement and redundancy more systematically. A GH1.25 connector supports GPS, SBUS, PPM, and CRSF receivers, while six PWM outputs are listed for ESC and servo connections.
Supporting 2 to 12S power is a notable advantage for aircraft that need a broad battery range, although the actual cell count must be reconciled with the connected ESCs and other components. The package includes the flight-controller motherboard, ribbon cable, and basic wiring, with some batches potentially including absorbers. The ESC is excluded, so this is a controller platform rather than a complete propulsion bundle.
The PIX 2-12S is well suited to builders creating a custom VTOL or multirotor around a 30.5-by-30.5-millimeter M2 mounting pattern. Before ordering, check the full pinout, connector orientation, sensor placement, and firmware documentation. Its clear specifications and protocol support make it a strong technical option, but the excluded ESC and lack of a supplied rating should be considered.
Support for SBUS, PPM, and CRSF gives builders several ways to connect a control link. A unified GH1.25 connection can simplify harness organization, although each aircraft should still be checked for voltage levels and signal compatibility.
The included gyroscope, magnetometer, and barometer provide a useful sensor foundation. Their placement away from motors, ESCs, and high-current wiring remains important because accurate measurements depend on a clean mechanical and electrical installation.
We may earn a commission when you buy through this link, at no additional cost to you.
The Pixhawk 2.4.8 PX4 Open Source Flight Controller is our editor's choice because it combines a well-established autopilot concept with broad applicability to fixed-wing, multirotor, helicopter, marine, and ground vehicles. It carries a 4.8 rating and is sold as a combo with GPS, giving new builders an important navigation component in the same purchase.
We may earn a commission when you buy through this link, at no additional cost to you.
Its controller uses an STM32F427 ARM Cortex-M4 processor with a 32-bit failsafe coprocessor and an MPU 6000 three-axis accelerometer. More importantly for VTOL development, the open-source architecture allows builders to work with rich modules and undertake secondary development. A fixed-wing wing and multirotor lift package can be treated as parts of a larger configurable platform rather than unrelated flight systems.
The practical trade-off is that this is not a turnkey stack. You must connect motors, servos, sensors, and other modules, then configure and calibrate the system. The supplied description says a quick-start guide is included for new players working with a DIY F450, although a guide aimed at multirotors may not fully explain a custom VTOL airframe. Older hardware may also offer fewer resources than newer H7 boards.
Choose the Pixhawk 2.4.8 if open-source flexibility, ecosystem familiarity, and cross-vehicle support matter more than having the newest processor. It is especially attractive for experimenters, educators, and developers who want to modify behavior. Confirm current firmware support, pin availability, and accessory compatibility before installation, and reserve ample time for configuration and bench testing.
The open-source foundation makes the Pixhawk attractive for builders who want to understand or alter flight behavior. PX4 provides a recognizable structure for mission planning, tuning, logging, and vehicle configuration, while the hardware can serve several unmanned vehicle types.
Including GPS in the listed combination removes one necessary navigation component from the initial build. It remains essential to position the antenna away from RF interference and to verify the module's orientation and protocol in the selected firmware.
We may earn a commission when you buy through this link, at no additional cost to you.
The F405 Wing Flight Controller is explicitly designed for fixed-wing drones with VTOL capabilities, giving it a clear conceptual fit for transition aircraft. It supports ArduPilot firmware and app-based configuration, two meaningful advantages for builders who want an established autonomous-flight environment and a convenient way to monitor or adjust parameters.
We may earn a commission when you buy through this link, at no additional cost to you.
The F405 processor is positioned as providing fast, stable control, while the lightweight, compact design is intended to minimize the burden on a small airframe. The supplied description also states compatibility with various fixed-wing drone models. Those attributes make the board appealing when the wing, propulsion arrangement, and control outputs must share a compact installation area.
The available information is less detailed than that for the PIX 2-12S, Pixhawk 6C, and the 30-by-30-millimeter stacks. The precise sensor set, dimensions, mounting pattern, output count, input voltage, and included wiring are not stated, and no customer rating is supplied. Those omissions make exact airframe matching difficult without consulting the seller's documentation.
We recommend the F405 Wing Flight Controller for builders seeking a dedicated fixed-wing VTOL board with ArduPilot and app support. Confirm that the advertised app and firmware combination is appropriate for your intended use, and verify every connector and mounting dimension. It may offer a more approachable path than assembling a general controller around a custom transition mechanism.
The board's stated fixed-wing VTOL focus distinguishes it from general-purpose multirotor stacks. A wing-specific layout can be attractive for compact aircraft where a dedicated transition controller is easier to wire than a full autopilot package.
ArduPilot support gives builders access to a widely used autonomous-flight framework, while the stated app control can simplify parameter review. The exact app capabilities should be confirmed for the firmware version and the hardware revision being purchased.
We may earn a commission when you buy through this link, at no additional cost to you.
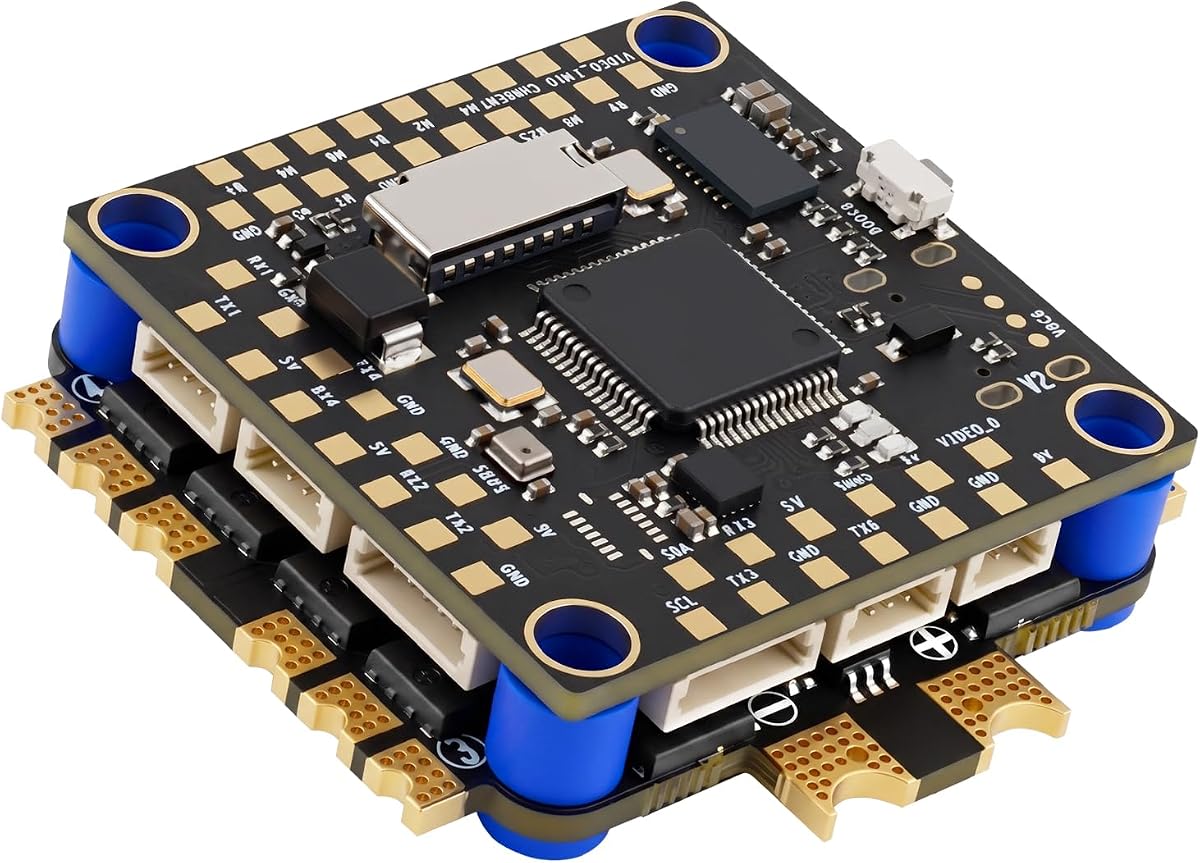
The CORVON H743 60A Stack combines an H743 flight controller with a four-in-one 32-bit ESC, reducing the number of major assemblies in a compact aircraft. The controller uses an STM32H743 processor rated at 480MHz and dual IMUs based on the BMI088 and BMI270. It also lists compass and barometer support, making it a sensor-rich platform for multirotor and hybrid VTOL concepts.
We may earn a commission when you buy through this link, at no additional cost to you.
Its integrated ESC is rated for continuous 60A per channel and more than 80A burst current, while supporting 2-to-8S LiPo batteries. That high current capacity may suit larger multirotor lift sections, although the actual continuous and burst capability of the complete stack should be treated as a design constraint rather than a target to approach continuously.
Connectivity is one of the strongest parts of the specification. Seven UART ports, 10 PWM outputs, CAN, I2C, and OSD support leave room for GPS, telemetry, cameras, receivers, and other peripherals. Betaflight, PX4, INAV, and ArduPilot support broadens the possible workflows, including autonomous VTOL experimentation when the board and its peripherals match the selected firmware.
This stack is best for builders wanting compact integration, abundant interfaces, and substantial ESC headroom in a 30.5-by-30.5-millimeter format. It does not include the entire aircraft, and the no-rating listing offers little customer-performance evidence. Check mounting clearance, cable routing, cooling, and current requirements carefully; powerful electronics still need adequate airflow and sound installation practices.
Combining the flight controller and ESC reduces board count and can simplify wiring in a small frame. The arrangement is particularly attractive for multirotor lift sections where compact integration and short motor leads are valuable.
Seven UARTs, 10 PWM outputs, CAN, and I2C provide substantial expansion room. These interfaces support the kind of sensor, telemetry, camera, and receiver mix often needed in a hybrid aircraft, subject to pin sharing and software support.
We may earn a commission when you buy through this link, at no additional cost to you.
The CORVON H743 50A Stack pairs a 480MHz STM32H743 flight controller with a four-in-one 50A ESC. Like the 60A version, it provides dual BMI088 and BMI270 IMUs, compass and barometer support, a 30.5-by-30.5-millimeter mounting pattern, and compatibility with Betaflight, INAV, PX4, and ArduPilot.
We may earn a commission when you buy through this link, at no additional cost to you.
Its 50A continuous-current rating and 2-to-6S battery range suit many mid-size multirotor applications. The ESC supports high-frequency PWM, DSHOT, and ONESHOT protocols for throttle response, while the H743 controller provides ample processing and memory for logs, telemetry, and autonomous configurations. The total combined weight is listed at 21.5 grams.
Its principal distinction from the 60A stack is the eight-bit ESC rather than a 32-bit ESC. That can affect motor-control characteristics, and the reduced maximum cell count may constrain larger builds. The stack is not supplied with a customer rating, so buyers should not infer real-world reliability from its specification sheet alone. The published information also does not replace a full pinout and assembly guide.
This model is a sensible middle ground for a compact VTOL's multirotor section when 50A per channel and a maximum 6S configuration are sufficient. It offers the same broad firmware and connectivity framework as the higher-current version, including seven UARTs, 10 PWM outputs, CAN, I2C, and OSD support. Confirm motor stall current, battery configuration, and thermal conditions before installation.
The 480MHz H7 platform provides a capable computational base for filtering, logging, and autonomous functions. Supporting four major firmware ecosystems gives builders room to select the workflow that best fits their experience and aircraft architecture.
At a listed 21.5 grams for the combined stack, the package preserves a manageable installation footprint. Its size and 30.5-square-millimeter pattern suit common frame layouts, although connector orientation and component clearance still need checking.
We may earn a commission when you buy through this link, at no additional cost to you.
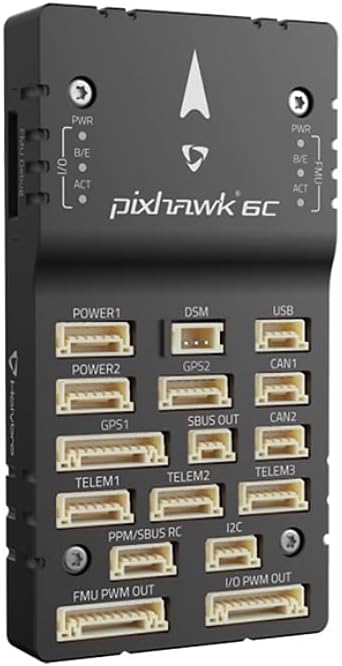
The Pixhawk 6C represents the most technically advanced standalone autopilot in this guide. It runs a 32-bit STM32H743 ARM Cortex-M7 processor at 480MHz, with 2MB of flash memory and 1MB of RAM, and comes with PX4 Autopilot preinstalled. It is designed for demanding autonomous aircraft, research, and professional development applications.
We may earn a commission when you buy through this link, at no additional cost to you.
Its sensor architecture is a major strength. Redundant IMUs come from Bosch and InvenSense, specifically the BMI055 and ICM-42688-P, allowing the system to cross-check orientation information. Integrated heating resistors help maintain consistent sensor temperature, while the engineered vibration-isolation system is intended to reduce high-frequency vibration and sensor noise during flight.
The controller also supports flexible peripheral integration. A hardware switch provides PWM signal modes of either 3.3V or 5V, while ArduPilot is supported with version 4.3 or later required for the M10 GPS. The plastic enclosure keeps the listed weight at 34.6 grams, compared with 59.3 grams for the durable aluminum option, making it possible to optimize for either weight or ruggedness.
This is our premium recommendation for builders who value sensor redundancy, isolation, processing headroom, and a professional open-source foundation. It is less convenient than a tiny ESC stack because of its larger 84.8-by-44-by-12.4-millimeter body, and no customer rating is supplied. Confirm mounting, vibration mounting, GPS compatibility, and wiring before it becomes part of a flight-critical build.
Using IMUs from two manufacturers adds a valuable layer of cross-checking. Combined with temperature control, this architecture is well suited to autonomous missions where sensor consistency and diagnostic information are more important than minimum weight.
The integrated isolation system is designed to suppress high-frequency airframe vibration before it reaches sensitive inertial sensors. Mechanical installation, soft mounting, and balanced hardware remain necessary because vibration control cannot be separated from the quality of the surrounding frame.
We may earn a commission when you buy through this link, at no additional cost to you.
The AERO SELFIE F405NC 60A Stack combines a 168MHz STM32F405 controller, dual BMI42688 inertial sensors, a DPS310 barometer, and a 60A four-in-one eight-bit ESC. It carries a 4.4 rating and is compatible with Betaflight, INAV, and ArduPilot, giving it a proven-consumer orientation along with support for autonomous experimentation.
We may earn a commission when you buy through this link, at no additional cost to you.
The integrated ESC is listed at 60A continuous current per channel and above 80A burst current, supported across 2-to-6S LiPo batteries. Six UART ports, 10 PWM outputs, I2C, and OSD support cover many common requirements, and the combined weight is listed at 23.2 grams. Its O3 and O4 AIR interface focus may be especially relevant to FPV-oriented aircraft.
The F405NC platform is less computationally expansive than the H743 alternatives, and CAN is not listed. PX4 compatibility is also absent from the stated firmware list, so this package is less convenient for a PX4-centered hybrid VTOL project. The ESC's eight-bit architecture and relatively high current rating should both be considered when selecting motors and operating conditions.
Choose this stack for a compact, integrated build that uses ArduPilot for VTOL experimentation or conventional flight-control firmware for the multirotor section. Its 4.4 customer rating provides more visible feedback than several unrated listings, although individual results can vary. Verify digital-camera compatibility, connector pinouts, current requirements, and whether ArduPilot supports every peripheral planned for the aircraft.
The 60A continuous per-channel ESC rating provides useful headroom for responsive multirotor propulsion. Matching motors to the ESC and battery system remains essential, particularly in a hybrid aircraft where the lift motors also operate during fixed-wing phases.
Two BMI42688 IMUs and an onboard DPS310 barometer provide a capable sensing foundation. Redundancy can improve confidence in orientation data, while careful sensor placement is needed to minimize vibration and electromagnetic interference.
We may earn a commission when you buy through this link, at no additional cost to you.
The AERO SELFIE H743 60A Stack combines a 480MHz STM32H743 controller with dual BMI088 and BMI270 IMUs, a compass, a barometer, and a four-in-one 32-bit 60A ESC. It supports Betaflight, INAV, PX4, and ArduPilot, making it one of the more versatile integrated packages for a compact hybrid VTOL's vertical-lift section.
We may earn a commission when you buy through this link, at no additional cost to you.
Its connectivity includes seven UART ports, 10 PWM outputs, CAN, I2C, and OSD support. These features leave considerable room for a receiver, GPS, telemetry, and other peripherals, while CAN is particularly useful in advanced vehicle architectures. The 32-bit ESC supports 2-to-6S LiPo operation and is rated at 60A continuous current per channel with more than 80A burst capability.
The main caution is the 3.7 customer rating, the lowest among the products with a visible score. It does not automatically make the hardware unsuitable, but it warrants closer attention to recent customer feedback, package contents, and possible firmware or hardware revisions. The integration is attractive, but the airframe's current demands and cooling requirements must be designed around rather than inferred from the headline rating.
This stack is a strong technical candidate for multirotor-derived hybrid aircraft that need H7 processing and PX4 or ArduPilot support in a 30.5-by-30.5-millimeter package. It is less suited to larger lift systems requiring an eight-cell configuration or greater continuous current. Confirm ESC wiring, motor direction, sensor orientation, and firmware support before finalizing the build.
Pairing a 480MHz controller with a 32-bit ESC creates a high-performance control chain. The result is well suited to responsive motor behavior, sophisticated filtering, logging, and autonomous functions when the selected firmware supports the full configuration.
Seven UARTs, 10 PWM outputs, CAN, and I2C create room for navigation, telemetry, and control accessories. A hybrid aircraft can use these connections to combine fixed-wing commands, vertical-lift control, and external sensor information, subject to the selected firmware's pin-sharing rules.
We may earn a commission when you buy through this link, at no additional cost to you.
Choosing a flight controller for a hybrid VTOL requires balancing transition reliability, sensor quality, software support, available outputs, physical constraints, and the level of autonomy the aircraft will actually need. The most important step is designing the complete aircraft around a controller whose documented capabilities match every required function.
A hybrid VTOL controller must handle a forward-flight wing, multiple lift motors, control surfaces, and the transition between those configurations. Confirm that the listed firmware explicitly supports the intended airframe, including VTOL transition logic, independent motor outputs, aileron and elevator control, and appropriate throttle mapping. A general multirotor controller can work only when its software and output layout accommodate the fixed-wing portion of the aircraft.
The processor determines how much filtering, telemetry, navigation, and autonomous logic can run comfortably. The STM32H743 boards listed here operate at 480MHz and provide substantial performance headroom, while the F405 options use a lower-frequency processor but remain appropriate for many conventional builds. Check the processor clock, flash memory, RAM, and firmware support together rather than assuming one specification guarantees a better aircraft.
Gyroscopes, accelerometers, magnetometers, and barometers form the controller's awareness of the aircraft. Dual or redundant IMUs can help identify inconsistent measurements, but they also demand careful vibration isolation and calibration. A magnetometer is especially important for directional missions, while a barometer contributes to altitude estimation. Check whether each sensor is on board, included as a bundle, or dependent on an external module.
Firmware determines what the hardware can realistically do. PX4 and ArduPilot are prominent choices for autonomous fixed-wing and VTOL missions, while Betaflight and INAV are often associated with manual-oriented multirotor and FPV applications. Confirm the exact controller revision is supported, review available VTOL parameters, and check whether essential functions such as GPS input, telemetry, failsafes, and mission planning are available for your chosen release.
A VTOL aircraft may need ESC signals for several lift motors, PWM or serial commands for ailerons and other surfaces, and a receiver link that works with the chosen firmware. The PIX 2-12S lists six PWM outputs plus SBUS, PPM, and CRSF support, while the H7 stacks list 10 PWM outputs and multiple UARTs. Count actual channels after reserving outputs for other equipment and check whether receivers share pins with telemetry or GPS.
Controller supply voltage and motor current are hard constraints. The PIX 2-12S accepts a broad 2-to-12S range, while the integrated stacks are generally limited to 2-to-6S or 2-to-8S. Their ESCs vary from 45A-class or 50A outputs to 60A versions. The stated title of one AERO SELFIE product mentions 60A, while the detailed description identifies a 45A ESC, so buyers should verify the exact package before relying on the headline specification.
The aircraft's available volume and center of gravity can eliminate a controller before firmware is considered. The PIX 2-12S measures 39 by 39 by 12 millimeters, the Pixhawk 6C uses a much larger 84.8 by 44 by 12.4-millimeter plastic enclosure, and several ESC stacks use a 30.5 by 30.5-millimeter pattern. Check not only hole spacing but also connector clearance, airflow, vibration damping, cable bend radius, and antenna placement.
Autonomous flight generally requires more than the controller itself. GPS, telemetry, compass, RC receiver, OSD, and camera interfaces must all fit together without conflicts. The Pixhawk 2.4.8 includes GPS in its listed combo, while the Pixhawk 6C and the 30-by-30-millimeter stacks expose UART, I2C, CAN, or other buses for expansion. Plan antenna placement and grounding as carefully as the pin assignments because navigation performance depends on the whole installation.
Begin with documentation rather than power. Identify the exact board revision, read the pinout and supported firmware instructions, verify the power range, and create a wiring diagram for every motor, control surface, receiver, GPS, telemetry module, and ESC. Confirm signal levels and connector orientation before inserting components. A bench test without propellers should be used to check receiver movement, motor direction, sensor orientation, failsafe behavior, and the configured transition sequence.
Install the controller in a vibration-controlled location, keeping inertial sensors away from motors, ESCs, high-current cables, and sources of magnetic interference. Route wiring neatly, use secure strain relief, provide cooling where required, and follow the manufacturer's mounting method. After installation, complete firmware setup, sensor calibration, compass calibration in the intended operating area, radio mapping, motor direction, and a full configuration review before adding power to the propulsion system.
For a hybrid VTOL, rehearse each flight phase independently: vertical hover, vertical takeoff, transition to fixed-wing flight, forward cruise, transition back, and vertical landing. Use simulation, altitude-limited tests, or a safely configured test area where appropriate. After every firmware update, motor or prop change, battery change, or major airframe modification, repeat the relevant calibration and failsafe checks. Maintain vibration logs, review warnings promptly, and keep the controller protected from moisture, impact, electrostatic discharge, and excessive temperature.
A dedicated VTOL controller is designed with fixed-wing surfaces and vertical-lift operation treated as a primary use case. A general multirotor controller may also fly a VTOL aircraft, but only when its firmware and outputs support the necessary transition logic, control surfaces, and motor arrangement. The dedicated product in this list is the KK 2.1.5, while several other options provide broader open-source flexibility.
Yes, when its firmware and hardware configuration support fixed-wing VTOL operation and the aircraft has compatible motors, servos, receivers, and navigation sensors. The Pixhawk 2.4.8 and Pixhawk 6C are strong candidates for open-source autonomous projects. You must still configure transition behavior, motor outputs, control surfaces, GPS, telemetry, and appropriate failsafes before flying.
An integrated stack can reduce the number of boards, shorten motor wiring, and save installation space. It does not remove the need to match motor current, battery voltage, signal protocols, frame mounting, and cooling. Integrated options are particularly convenient for compact multirotor lift sections, while standalone controllers may offer more freedom for unusual airframe layouts.
Dual inertial measurement units provide two sets of motion and orientation data that the system can compare. If one sensor produces an implausible result, redundancy may help the autopilot identify an inconsistency rather than trusting a single measurement stream. The benefit still depends on correct calibration, vibration isolation, sensor placement, and firmware support for the selected board.
Both can support advanced fixed-wing and VTOL projects, but the better choice depends on your experience, mission software, ground-control setup, and required peripherals. PX4 is preinstalled on the Pixhawk 6C, while the Pixhawk 2.4.8 is presented as a PX4 combination. Several compact stacks list both, making it useful to compare mission interfaces and community resources before configuring the board.
The controller and ESC must support the voltage produced by the selected battery configuration. The PIX 2-12S supports 2 through 12 cells, while most integrated stacks in this guide are limited to 6 or 8 cells. Exceeding a board's range can damage electronics, so battery count, connector type, current draw, and motor requirements should be finalized before installation.
An autonomous VTOL normally needs a compatible GPS or other positioning source for navigation and mission execution. The Pixhawk 2.4.8 is listed as a combination with GPS, while other controllers may require an external module. GPS placement, antenna orientation, cable routing, and electromagnetic interference all affect the quality of the position solution.
Remove propellers and perform a complete bench test of receiver channels, motor directions, sensor readings, compass heading, and failsafes. Then test vertical hover and transition behavior in a safe area with appropriate abort procedures. Repeat relevant calibration after changes to firmware, motors, propellers, battery configuration, or airframe mass, because a successful bench test does not guarantee safe transition flight.
The best fit depends on the aircraft's architecture and the pilot's software priorities. The KK 2.1.5 stands out for dedicated VTOL and V-tail support, the Pixhawk 2.4.8 offers a well-known open-source foundation with GPS, and the Pixhawk 6C provides the strongest premium sensor architecture with redundant IMUs, thermal control, and vibration isolation.
For compact hybrid builds, the CORVON and AERO SELFIE stacks offer an attractive combination of H7 or F405 processing, an integrated ESC, extensive outputs, and broad firmware support. Before choosing one, prioritize motor current, battery count, sensor placement, transition logic, receiver compatibility, and the amount of physical room available. The most capable controller is useful only when the entire electrical and mechanical installation supports it correctly.
Finally, check the current product listing, documentation, package contents, accessory requirements, and availability before purchasing. Firmware revisions and hardware bundles can change, and product pricing also changes over time. Compare the current specifications with your complete parts list, then bench-test the controller and validate the transition sequence before trusting it with an airborne VTOL aircraft.